
Next-Generation Vascular Intervention: Integrating Micro Medical Robots with Magnetic Field Control
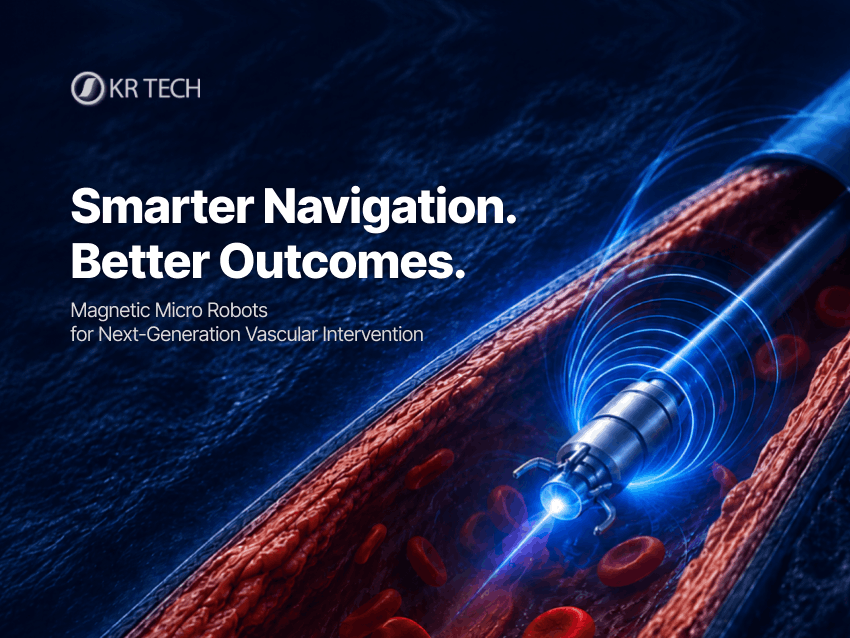
Next-Generation Vascular Intervention: Integrating Micro Medical Robots with Magnetic Field Control
Cardiovascular disease is cited as one of the leading causes of death worldwide, and Chronic Total Occlusion (CTO), where blood vessels become completely blocked, is known as a major challenge in the field of vascular intervention. CTO refers to a condition where blood vessels have calcified or become occluded over a long period, making treatment difficult with conventional catheter-based procedures alone.
Recently, medical technology has evolved beyond simply developing more sophisticated equipment to providing more precise support for the judgment and manipulation of medical professionals. Recognizing this shift, KR TECH is integrating precision magnetic field control technology accumulated in the industrial field into medical systems and is presenting new possibilities for next-generation vascular intervention technology through its magnetic field-based micro medical robot platform.
Physical Limitations of Cardiovascular Intervention
CTO procedures are considered to be highly demanding within the field of vascular intervention. Operators must navigate the occluded vessel using a guidewire, but they must perform the procedure relying on limited imaging information and experience in an environment where they cannot directly visualize the inside of the vessel.
In particular, when the lesion is long or severely calcified, situations may arise where the guidewire deviates from the target path or fails to pass through the lesion. As procedure times lengthen, the burden of radiation exposure for both patients and medical staff increases, and the use of contrast agents may also increase, along with the risk of vascular damage.
As such, conventional catheter-based procedures rely heavily on the proficiency of medical personnel, and the difficulty and burden of the procedure become even greater in complex lesions. Accordingly, the medical community is conducting various technological studies to realize a more precise and predictable vascular interventional environment.
Precision Magnetic Field Control: The Core Engine of Micro Medical Robots
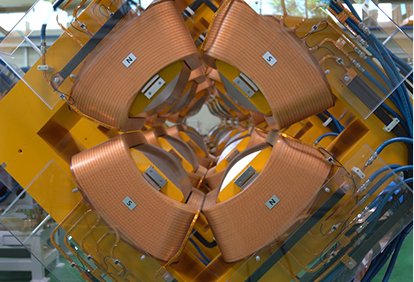
The core of the digital medical solution presented by KR TECH is to transform the uncertainty of manual procedures into a data-driven, predictable control environment. Based on precision magnetic field vector design technology utilizing 2D/3D Finite Element Method (FEM) analysis, we are researching magnetic field navigation technology in which an ex vivo electromagnet system controls the movement of micro-medical robots within the body.
Furthermore, we are pursuing the development of image information navigation systems utilizing ultrasound and 3D X-ray imaging, as well as catheter position feedback algorithms, focusing on the advancement of position control and procedure assistance technologies for magnetic field-based micro-medical robots. The academic basis for this precision control technology is a Compensation Algorithm that corrects in real-time the variability in coil resistance and inductance caused by frequency changes in Electromagnetic Actuation (EMA) systems. Related research has confirmed that applying this algorithm can improve the locomotion precision of magnetic field-based micro-robots and enable more stable hammering motion (Jeong et al., 2015).
New Possibilities Enabled by Ultra-Precision Actuation Solutions
KR TECH is conducting research on a hybrid drive mechanism that combines the physical thrust of a guide wire with the magnetic field steering function of a tip micro-medical robot.
This technology aims to control the orientation of micro-medical robots within blood vessels and support more effective access to target areas, even in complex vascular structures or occluded sections.
In particular, the development of Micro-Drilling technology utilizing a hammering-based tunneling mechanism presents new possibilities for lesion sites that are difficult to access using conventional methods.
Related research has confirmed that electromagnetic actuation-based micro-robots with applied compensation algorithms can achieve stable movement and access to occluded sections in vascular phantom experiments and animal experiment environments. In addition, the possibility of passing through occluded blood vessel sites through tunneling functions based on hammering motion was also presented (Jeong et al., 2015).
These research results demonstrate the potential for magnetic field-based micro medical robots to be utilized as intravascular navigation and treatment assistance technologies in the future.
Based on this, KR Tech is continuing its research on magnetic field-based vascular intervention technology and is striving to secure more precise steering and position control technologies.
Expanding the Value of Technology: Solutions for Challenging Vascular Treatments
KR TECH is applying precision magnetic field control technology, accumulated in the industrial sector, to the research and development of medical micro-robot platforms.
Based on this foundation, we are researching next-generation vascular interventional technology that combines image navigation technology with precision control algorithms, and are pursuing the development of solutions capable of more sophisticated positional control even in complex vascular environments.
This control system provides a technical approach to enhance positional control precision and reduce the risk of vascular damage during procedures.
Furthermore, according to our business objectives, we aim to overcome the limitations of existing CTO procedures by applying micro-drilling technology, minimizing radiation exposure time during procedures, reducing contrast agent usage, and decreasing bleeding and complications.
Ultimately, we intend to contribute to establishing a safer and more efficient vascular interventional environment by reducing the operational burden on medical staff and supporting data-driven decision-making.
Setting the Standard for Next-Generation Vascular Therapy: KR TECH's Vision
Vascular interventional procedures are expected to evolve in a more precise and data-driven direction in the future. Moving away from traditional methods that relied on the experience and proficiency of medical professionals, a new procedural environment combining precision sensors, imaging technology, and intelligent control technology is required.
KR TECH is responding to these changes through the convergence of magnetic field control technology and micro medical robots. Our goal is to enhance the safety and predictability of vascular interventional procedures and provide an environment where medical professionals can perform procedures more efficiently.
Moving forward, KR TECH will continue to develop next-generation vascular interventional platforms based on precision magnetic field control technology, securing the trust of the medical field while growing into a global magnetic field solution company.
References
Jeong, S., et al. (2015). “Therapeutic Intravascular Microrobot through Compensation of Resistance and Mutual Inductance in Electromagnetic Actuation System.” International Journal of Control, Automation and Systems, 13(6), 1466-1473.